How Euler Angles Work
3-Second Blueprint (English)
- Euler angles represent any complex 3D orientation by chaining three elementary rotations around coordinate axes.
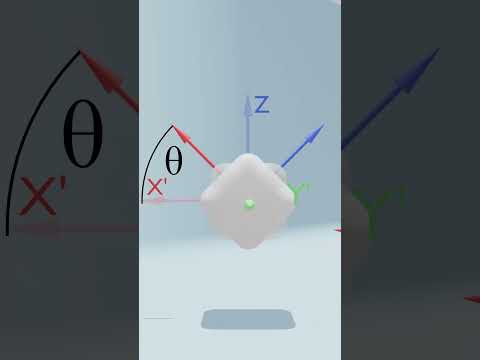
- In a Z-Y-X sequence, rotating first about the world Z-axis carries X and Y into new local axes X' and Y'.
- Subsequent rotations by theta about local Y' and phi about updated X' establish the final 3D reference frame.
Euler anglesZ-Y-X rotation sequenceWorld reference frameLocal coordinate axes3D orientation kinematics
3-Sekunden-Fazit (Deutsch)
- Euler-Winkel stellen jede komplexe 3D-Orientierung durch drei verkettete Elementardrehungen um Koordinatenachsen dar.
- In einer Z-Y-X-Folge dreht die erste Rotation um die Z-Achse die Achsen X und Y in neue lokale Achsen X' und Y'.
- Folgedrehungen um Winkel Theta um Y' und Phi um die neue X'-Achse erzeugen das endgültige 3D-Koordinatensystem.
Euler-WinkelZ-Y-X-DrehreihenfolgeWeltkoordinatensystemLokale Körperachsen3D-Rotationskinematik
Note / Hinweis: Blueprints are AI-generated educational summaries (0% Politics · 0% Religion · 0% Brainrot) and do not constitute medical, legal, or financial advice. / KI-generierte Zusammenfassung zu Bildungszwecken – ersetzt keine medizinische, rechtliche oder finanzielle Fachberatung.