PID Control - A brief introduction
3-Second Blueprint (English)
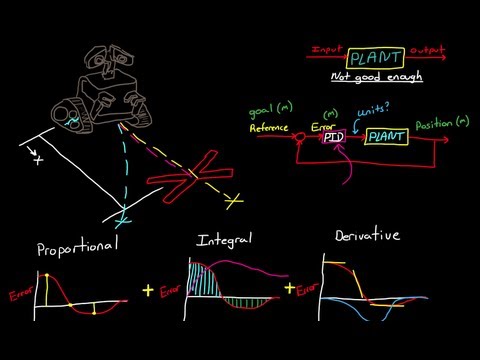
- Open-loop control sends fixed commands without position feedback, whereas closed-loop control measures error to correct drift.
- A PID controller sums proportional (Kp), integral (Ki), and derivative (Kd) paths to convert measured error into plant inputs.
- The integral path accumulates error area over time to eliminate constant steady-state offsets, while derivative tracks error rate.
PID ControllerClosed-Loop FeedbackError SignalIntegral Steady-State CorrectionDerivative Rate Action
3-Sekunden-Fazit (Deutsch)
- Offene Steuerungen senden feste Befehle ohne Rückkopplung, während geschlossene Regelkreise den Messfehler aktiv korrigieren.
- Ein PID-Regler summiert Proportional- (Kp), Integral- (Ki) und Differentialpfad (Kd), um den Fehler in Stellgrößen zu wandeln.
- Der I-Anteil integriert den Fehler über die Zeit gegen bleibende Regelabweichungen, der D-Anteil reagiert auf Änderungsraten.
PID-ReglerGeschlossener RegelkreisRegelabweichung (Error)Integralanteil (Ki)Differentialanteil (Kd)
Note / Hinweis: Blueprints are AI-generated educational summaries (0% Politics · 0% Religion · 0% Brainrot) and do not constitute medical, legal, or financial advice. / KI-generierte Zusammenfassung zu Bildungszwecken – ersetzt keine medizinische, rechtliche oder finanzielle Fachberatung.