Model Predictive Control
3-Second Blueprint (English)
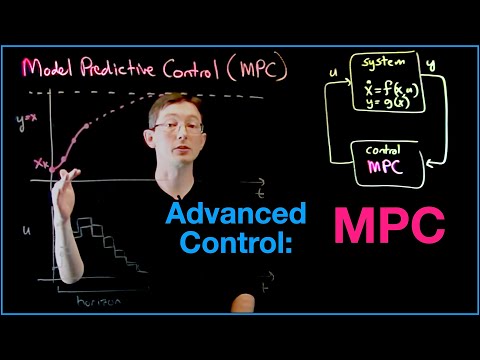
- Model Predictive Control uses a dynamic system model to simulate future state trajectories and optimize control inputs over a finite window.
- At each time step, only the first optimal control action is applied before shifting the horizon forward and re-optimizing from new states.
- Online receding-horizon optimization handles actuator limits and nonlinear dynamics that fixed offline LQR gains cannot easily accommodate.
Model Predictive ControlReceding HorizonTrajectory OptimizationNonlinear Dynamics
3-Sekunden-Fazit (Deutsch)
- Modellprädiktive Regelung nutzt ein Systemmodell, um künftige Zustandsverläufe vorherzusagen und Stellgrößen im Zeitfenster zu optimieren.
- Pro Zeitschritt wird nur der erste Stellbefehl umgesetzt, bevor der Horizont vorrückt und aus dem neuen Zustand erneut optimiert wird.
- Die fortlaufende Online-Optimierung beherrscht Stellbegrenzungen und nichtlineare Dynamiken, an denen feste Offline-LQR-Regler scheitern.
Modellprädiktive RegelungGleitender HorizontTrajektorienoptimierungNichtlineare Systeme
Note / Hinweis: Blueprints are AI-generated educational summaries (0% Politics · 0% Religion · 0% Brainrot) and do not constitute medical, legal, or financial advice. / KI-generierte Zusammenfassung zu Bildungszwecken – ersetzt keine medizinische, rechtliche oder finanzielle Fachberatung.